As our skies increasingly crowd with buzzing, hovering, flitting drones, spare a thought for the humble hopping robot.
As our skies increasingly crowd with buzzing, hovering, flitting drones, spare a thought for the humble hopping robot.
Hopping, a popular form of locomotion in the insect and amphibian worlds, is nearly two orders of magnitude more energy-efficient than flying. Unlike a mosquito that must constantly expend energy to stay aloft, a flea only works out when it jumps. Those cost savings could also pay off in the world of robotics: A group of small, simple hopping robots could explore a location much more cheaply than flying drones. These robots could find gas leaks in an oil refinery, monitor water and fertilizer usage on a farm, or even explore other planets.
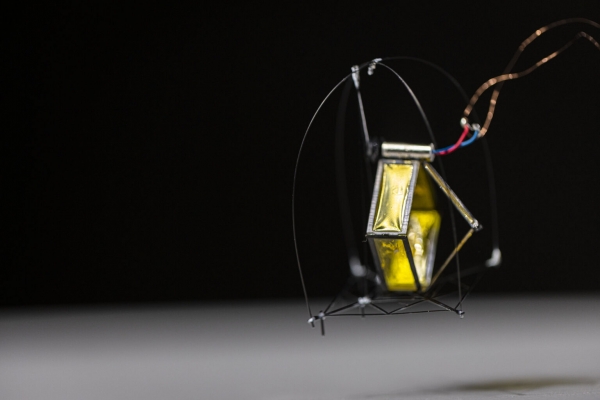
With this in mind, engineers at the University of Washington have created DirectHop, a roughly 1-gram robot that can perform multiple hops in sequence and jump high enough to clear a standard stair step. The robot uses a tiny electric motor and three folding legs to launch itself to a specified jump height with single centimeter accuracy. After it lands, DirectHop can twitch to right itself and then ready for another jump.
The prototype, which fits in the palm of a hand, represents multiple steps on the path to an autonomous hopping robot that can traverse a variety of environments.
Read More: University of Washington
Image: DirectHop, a 1-gram hopping robot developed at the University of Washington, leaps off of a tabletop. Unlike more common spring-loaded hopping bots, DirectHop is powered directly by a tiny motor, allowing it to precisely vary its jump height. Photo: Mark Stone/University of Washington